- Focus
- Power and machines, Software and automation
- Main tools
- PLC ladder logic, IEC 61131-3, Modbus TCP/IP, HMI
- Headline result
- Test pass rate: 100 %
Ladder-logic control of a hydraulic excavator arm that sorts four rock types, with safety interlocks and Modbus TCP/IP monitoring.
Problem
A manufacturing site needed a hydraulic arm with three articulated sections and a gripper to sort siltstone, limestone, gypsum and sandstone, with safe stopping and live monitoring.
What I built
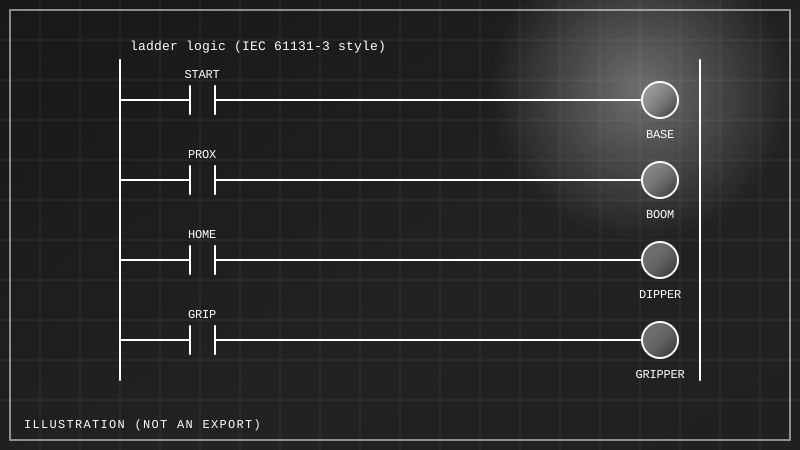
- A 10-rung ladder program following IEC 61131-3, with a sequenced, modular structure and timer-pulse blocks for each movement phase.
- I/O allocation for 5 digital inputs and 8 digital outputs.
- Safety interlocks: emergency stop, machine guards and fault indication with a 100 ms response.
- Modbus TCP/IP between the PLC and an HMI for real-time monitoring.
- Staged testing from components to subsystems to full cycles; two faults were found and fixed (short cylinder timers and a wrongly configured gripper contact).
Tools and standards
- PLC ladder logic
- IEC 61131-3
- Modbus TCP/IP
- HMI
Result
All test sequences passed after the two fixes: homing, arm positioning, gripper logic, emergency stop and full operation.
| Metric | Value | Source |
|---|---|---|
| Test pass rate | 100 % | Author's engineering portfolio (PDF) |
| Average cycle time | 35 s per rock | Author's engineering portfolio (PDF) |
| Start-to-motion delay | under 100 ms | Author's engineering portfolio (PDF) |
Visuals
Sources
- Author's engineering portfolio (PDF)